


CVPR 2022
P3Depth: Monocular Depth Estimation with a Piecewise Planarity Prior
Real-world 3D scenes have a high degree of regularity. We propose a method which can exploit this regularity, by implicitly learning intermediate representations that contain useful information about local planes in the scene. The proposed end-toend model predicts high-quality depth maps with sharp edges at occlusion boundaries, which yield consistent 3D reconstructions.
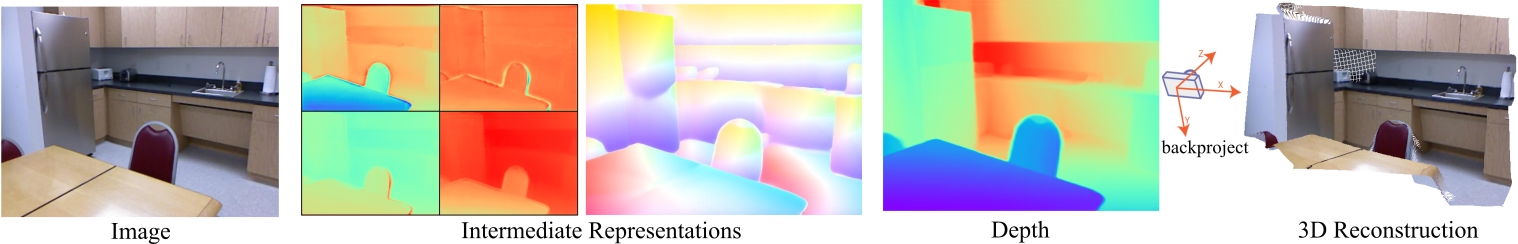
Our end-to-end P3Depth method uses the offset vector field to define interactions between pixels within a plane coefficient representation. The plane coefficients of seed pixels are used to predict depth at each position. The resulting prediction is adaptively fused with the initial prediction based on the confidence map to account for potential deviations from precise local planarity.

Results
NYU Depth v2:

KITTI:

Citation
@inproceedings{P3Depth,
  author    = {Patil, Vaishakh and Sakaridis, Christos and Liniger, Alexander and Van Gool, Luc},
  title     = {{P3Depth}: Monocular Depth Estimation with a Piecewise Planarity Prior},
  booktitle = {Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)},
  year      = {2022},
} This page was created by Vaishakh Patil. All rights reserved.